What Is a Magnetic Encoder Ring?
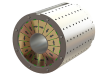
A magnetic encoder ring is a ring-shaped magnetic component used to provide position or angle feedback in robotics and automation systems. It works together with a magnetic sensor to generate signals based on the changing magnetic field as the ring rotates.
In many practical applications, magnetic encoder rings are used in compact motion control assemblies where installation space is limited but stable sensing performance is still required.
Among these applications, humanoid robot joints are one of the more demanding examples, as they often involve hollow shaft structures, high positioning requirements, and tight dimensional constraints. For this reason, the development of a high-precision magnetic encoder ring is not only related to ring geometry, but also to pole design, track arrangement, and magnetization accuracy.

Why Magnetic Encoder Rings Matter in Robotics and Automation
Magnetic encoder rings are used in robotics and automation systems where reliable position feedback must be achieved within limited installation space. Compared with some other sensing solutions, they are well suited to compact rotating structures and can be integrated into designs that require a ring-shaped magnetic target. In practical applications, this may include servo systems, compact actuators, and other motion control assemblies where stable angle detection is important.
Among these applications, humanoid robot joints are one of the more demanding examples. These systems often combine hollow shaft structures, limited radial space, and high requirements for positioning performance, which means the magnetic encoder ring must fit not only the sensing task, but also the surrounding structural and integration conditions. In this sense, the encoder ring is not simply a magnetic part, but an important element in the overall motion feedback design.
Single-Track and Multi-Track Magnetic Encoder Ring Designs
Magnetic encoder rings can be designed in different signal structures according to the sensing method and system requirements. In relatively straightforward applications, a single-track design may be sufficient to provide incremental position feedback through one magnetic pole pattern around the ring. This type of structure is generally easier to develop and manufacture, especially when the sensing logic and resolution target are relatively simple.
For more demanding systems, magnetic encoder rings may use two or more magnetic tracks on the same ring. One important example is the use of the Nonius, or Vernier, principle in absolute position sensing.
In this approach, the ring typically includes a master track with a higher number of poles and a second track with a slightly different pole count, such as N-1 or N+1. By comparing the phase relationship between these tracks, the encoder system can determine the absolute angular position over a full 360° rotation, including after power cycling.

In more complex designs, an additional index track may also be introduced for zero-point reference or system redundancy. As the track structure becomes more complex, the requirements for pole layout, dimensional consistency, and magnetization accuracy also become much higher. For this reason, the difference between single-track and multi-track magnetic encoder rings is not only a matter of layout, but also a reflection of the overall development difficulty.
Why Precision Magnetization Matters in Magnetic Encoder Rings?
In magnetic encoder ring development, precision magnetization is critical because the sensing performance depends not only on the ring structure itself, but also on how accurately the magnetic pole pattern is written onto the ring. Even when the dimensional design is correct, insufficient magnetization accuracy may still lead to unstable signal output, reduced resolution performance, or difficulties in sensor calibration. For this reason, magnetic encoder rings used in higher-end applications are not simply ordinary multipole rings with more poles, but magnetic components that require tighter control over the magnetization result.
This becomes even more important when the ring uses narrow pole pitch or multiple tracks. As the pole spacing becomes smaller and the magnetic layout more complex, the requirements for pole position consistency, track-to-track relationship, and overall signal uniformity all increase. In these cases, the magnetization process is closely related to the final sensing quality, rather than being treated as a separate downstream step.
For high-precision magnetic encoder rings, the key challenge is not only whether the ring can be magnetized, but whether the required magnetic pattern can be reproduced in a controlled and repeatable way. This is also one of the main reasons why magnetic encoder ring development often involves more than material selection and ring machining alone.
Challenges in High-Precision Encoder Ring Development
As the pole pitch becomes narrower and the track layout more complex, high-precision encoder ring development begins to face physical limitations that are not usually critical in ordinary multipole ring magnetization. In multi-track structures, unwanted magnetic interaction between adjacent poles or tracks may affect signal consistency, while sequential errors in the magnetization result can accumulate and reduce overall sensing quality. These issues become especially important when the encoder ring is expected to support high-resolution or absolute position feedback.
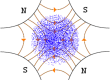
To address these limitations, high-precision magnetic encoder rings may require a more controlled magnetization approach. Rather than magnetizing the ring as a bulk pole pattern, the process can be closer to writing a defined magnetic sequence pole by pole. This helps reduce cross-talk between neighboring magnetic features and gives tighter control over key signal-related factors such as pitch consistency, cumulative pole position error, and harmonic distortion. For multi-track encoder rings, this level of control is often essential to maintain the required relationship between tracks.
For this reason, the development difficulty of a magnetic encoder ring is not determined by ring shape alone. In many cases, the real challenge lies in whether the magnetic pattern can be generated with sufficient precision and repeatability to support the intended sensing performance.
Custom Options for Magnetic Encoder Rings
Magnetic encoder rings can be developed with different physical and magnetic parameters according to the sensing system and mechanical structure. Typical custom variables may include outer diameter, inner diameter, thickness, pole count, pole pitch, number of tracks, magnetization direction, and whether the ring needs to be integrated with a carrier or related structural part. Depending on the project, material selection and ring construction may also need to be matched to the target sensing and assembly conditions.
In many high-precision robotics and automation projects, the signal logic is largely defined by the encoder chip, while the actual mechanical layout is determined by the joint or actuator structure. In practice, these two sides do not always match the limited dimensions of off-the-shelf encoder magnets. For this reason, custom magnetic encoder ring development often focuses not only on the physical size of the ring, but also on how to maintain the required pole logic within a non-standard geometry.
When the encoder chip requires a defined pole relationship, such as a specific pole count or multi-track structure, the ring dimensions may still need to be adjusted to fit the actual hollow shaft diameter or surrounding installation space. In such cases, the development value lies in applying the required magnetic logic to a custom ring size while keeping the intended sensing relationship intact. This is also one of the main reasons why magnetic encoder rings for demanding applications are often developed as project-specific parts rather than selected only from standard catalog sizes.
Work with SDM on Custom Magnetic Encoder Ring Projects
For magnetic encoder ring projects used in robotics and automation, the challenge is often not limited to selecting a magnetic material or defining a ring shape. In many cases, the more critical task is to match the required magnetic pole logic to the actual mechanical structure, especially when the available installation space, hollow shaft diameter, or track arrangement does not fit standard ring sizes.
At SDM Magnetics, we focus on custom magnetic encoder ring development based on project-specific sensing and structural requirements. This may include support for pole count matching, pole pitch adjustment, multi-track layout, and magnetization development for non-standard ring geometries. For applications such as humanoid robot joints and other compact motion control systems, this kind of coordination is often essential to achieving the intended sensing performance.
If you are developing a magnetic encoder ring for humanoid robot joints or other compact motion control systems, feel free to share your encoder chip requirements, target dimensions, or existing design conditions with us. We will review the project based on the required magnetic logic and structural constraints.